01 Research & projects

Work I've designed, built, tested, and presented

My projects sit where software meets hardware: perception, autonomy, and systems that have to keep working when the environment stops cooperating. Below is what I've actually built, what I found, and the questions I'm still working on.

Rescue Reach: disaster-response robotics combining UAV platforms, LiDAR, and thermal imaging

Featured · 2023 — present · Founder & lead engineer

Rescue Reach

Autonomous systems for disaster response

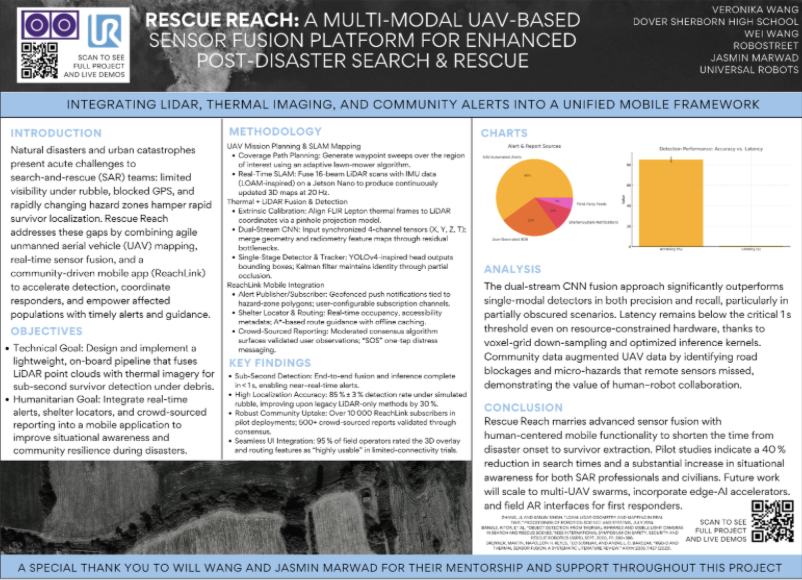
Exploring how robotics, computer vision, sensing, and coordination can improve situational awareness during the first hours after a disaster. A UAV platform fuses 16-beam LiDAR with FLIR thermal imagery through a dual-stream CNN running on a Jetson Nano; ReachLink handles alerts and community reporting; and ReachOne, the wearable multi-arm prototype, addresses what happens once a responder actually arrives.
  • Robotics
  • Computer Vision
  • Sensor Fusion
  • SLAM
  • Disaster Response

Read the full case study →

02 Other technical work

Robotics, research, and applied mathematics

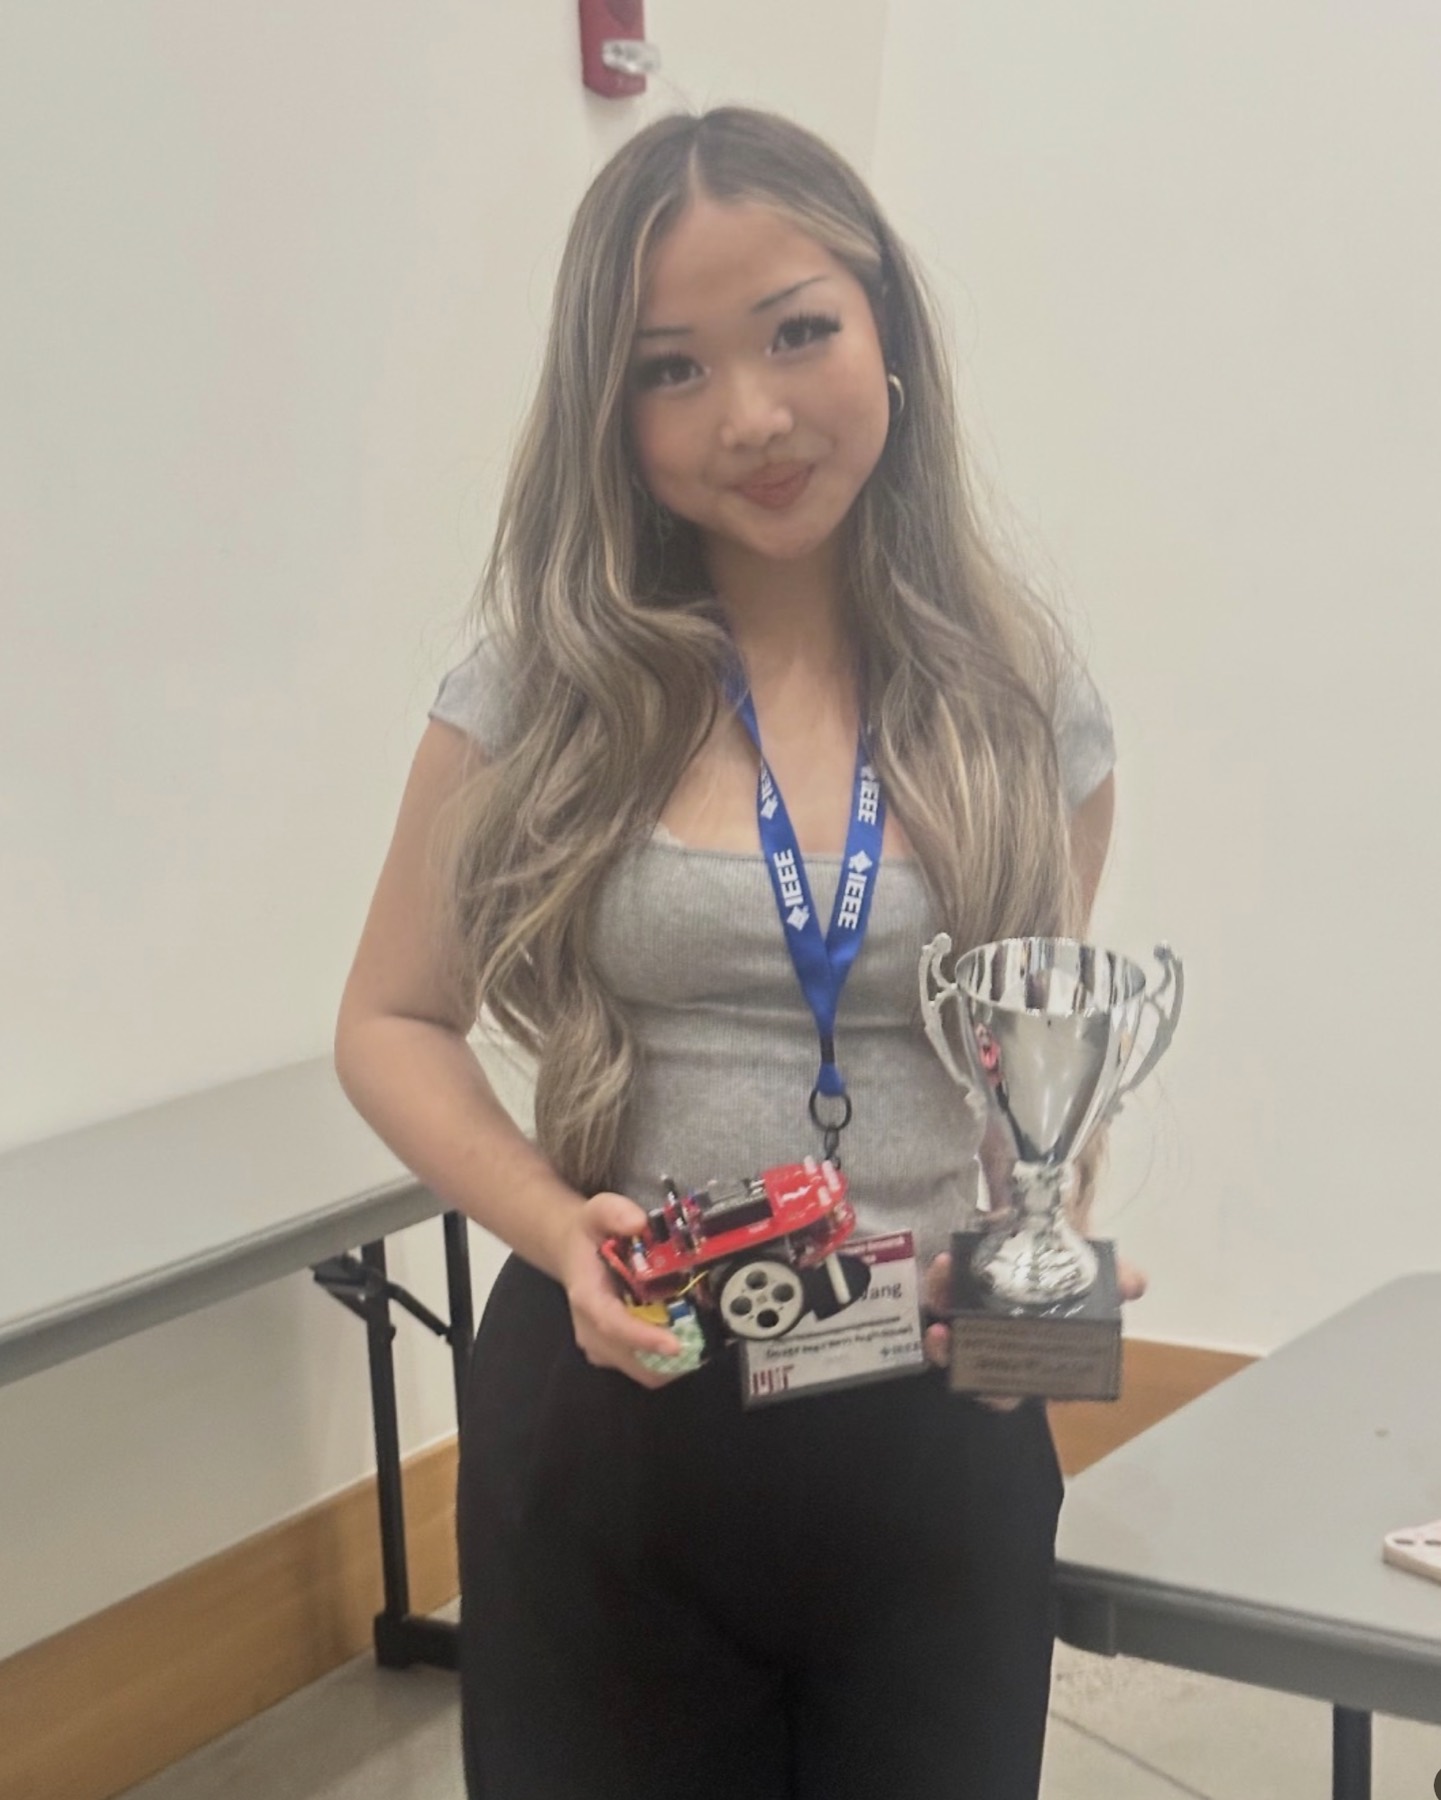
Veronika Wang holding her micromouse robot and trophy at the IEEE MIT Micromouse competition

Autonomous micromouse

Built and tuned an autonomous maze-solving robot for the IEEE MIT Micromouse competition, where our run placed 2nd nationally. The problem is a compact version of real autonomy: the robot has to sense walls, localize itself, search the maze, and then commit to the fastest route it has found.

  • Embedded control
  • Search algorithms
  • Sensing
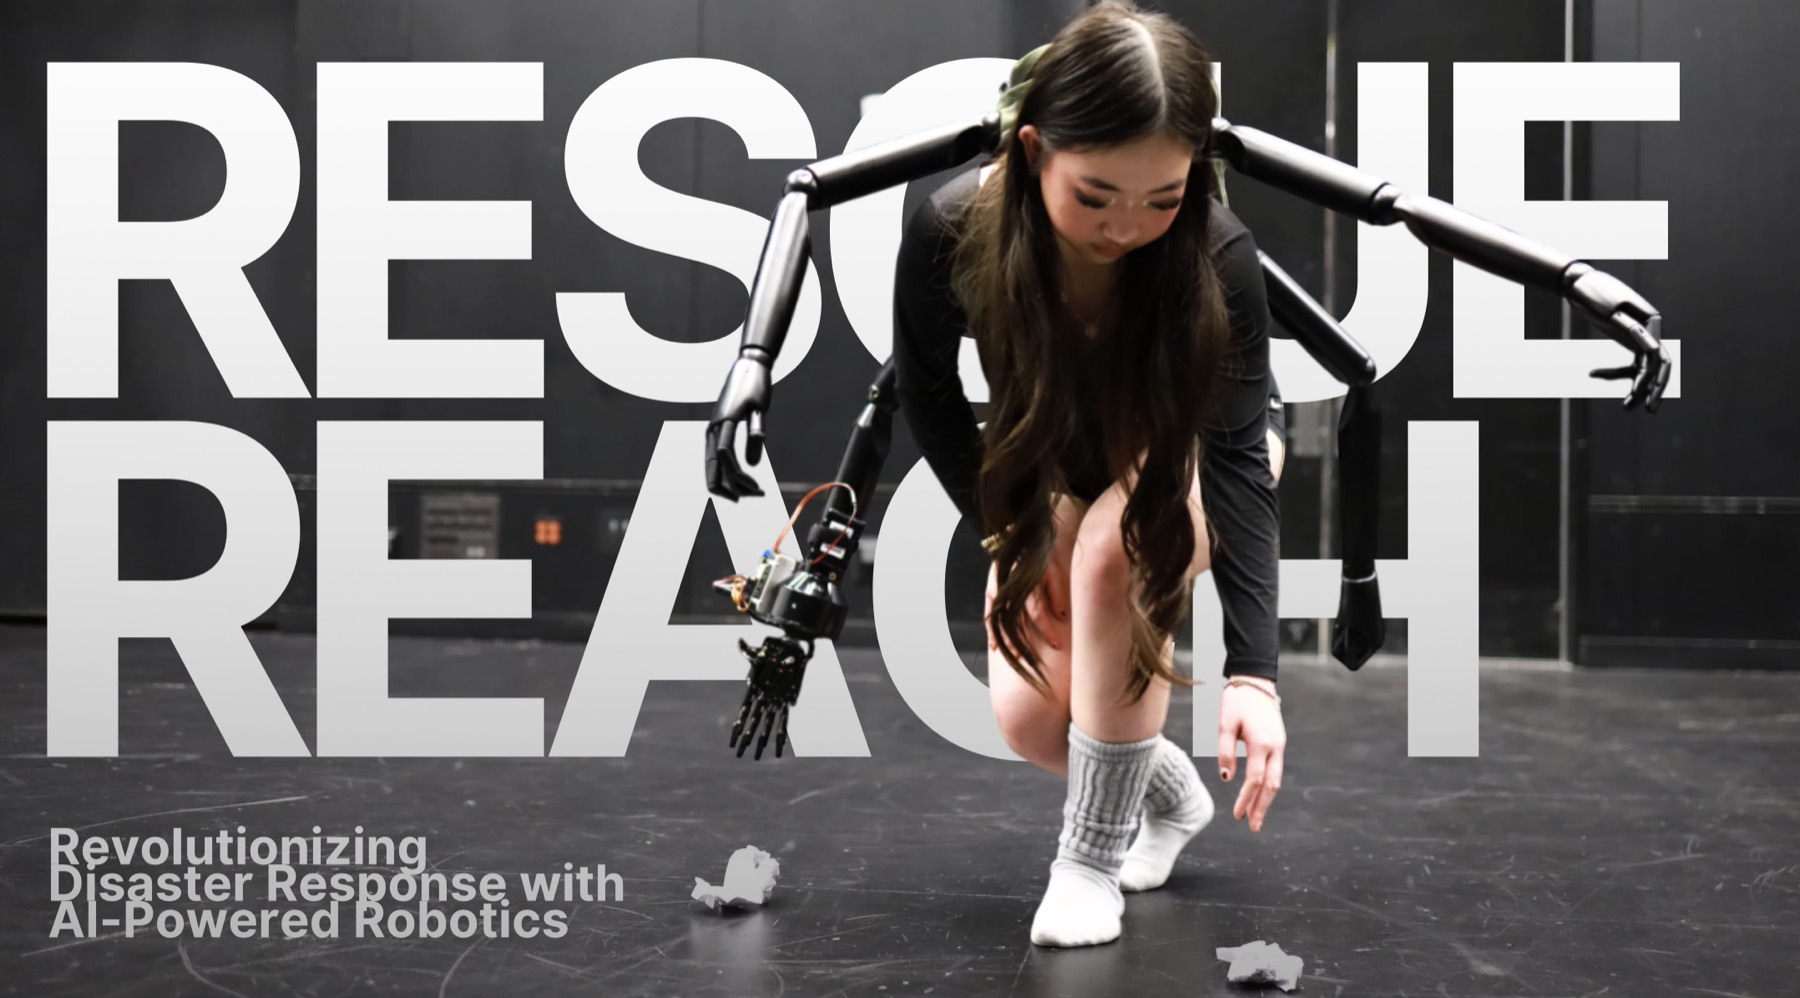
ReachOne branding: wearable robotics that extend human capability

ReachOne — wearable multi-arm robotics

A lightweight multi-arm robotic system worn like a backpack, built on the premise that in emergencies people don't lack courage, they lack hands. Modular arms, AI-assisted but human-controlled, designed around trust and safety. Currently a working prototype in movement testing.

  • Wearable robotics
  • Mechanical design
  • Shared autonomy
Research poster on the Rescue Reach multi-modal UAV sensor fusion platform

Research communication

I've presented this work as posters and talks: at the 2025 Global Green Development Summit at Stanford, where the poster received an Outstanding Award, at the Massachusetts Science & Engineering Fair, and at the Thermo Fisher Junior Innovators Challenge. Preparing for judges who aren't roboticists has repeatedly exposed weak assumptions in my design.

  • Poster
  • Technical writing
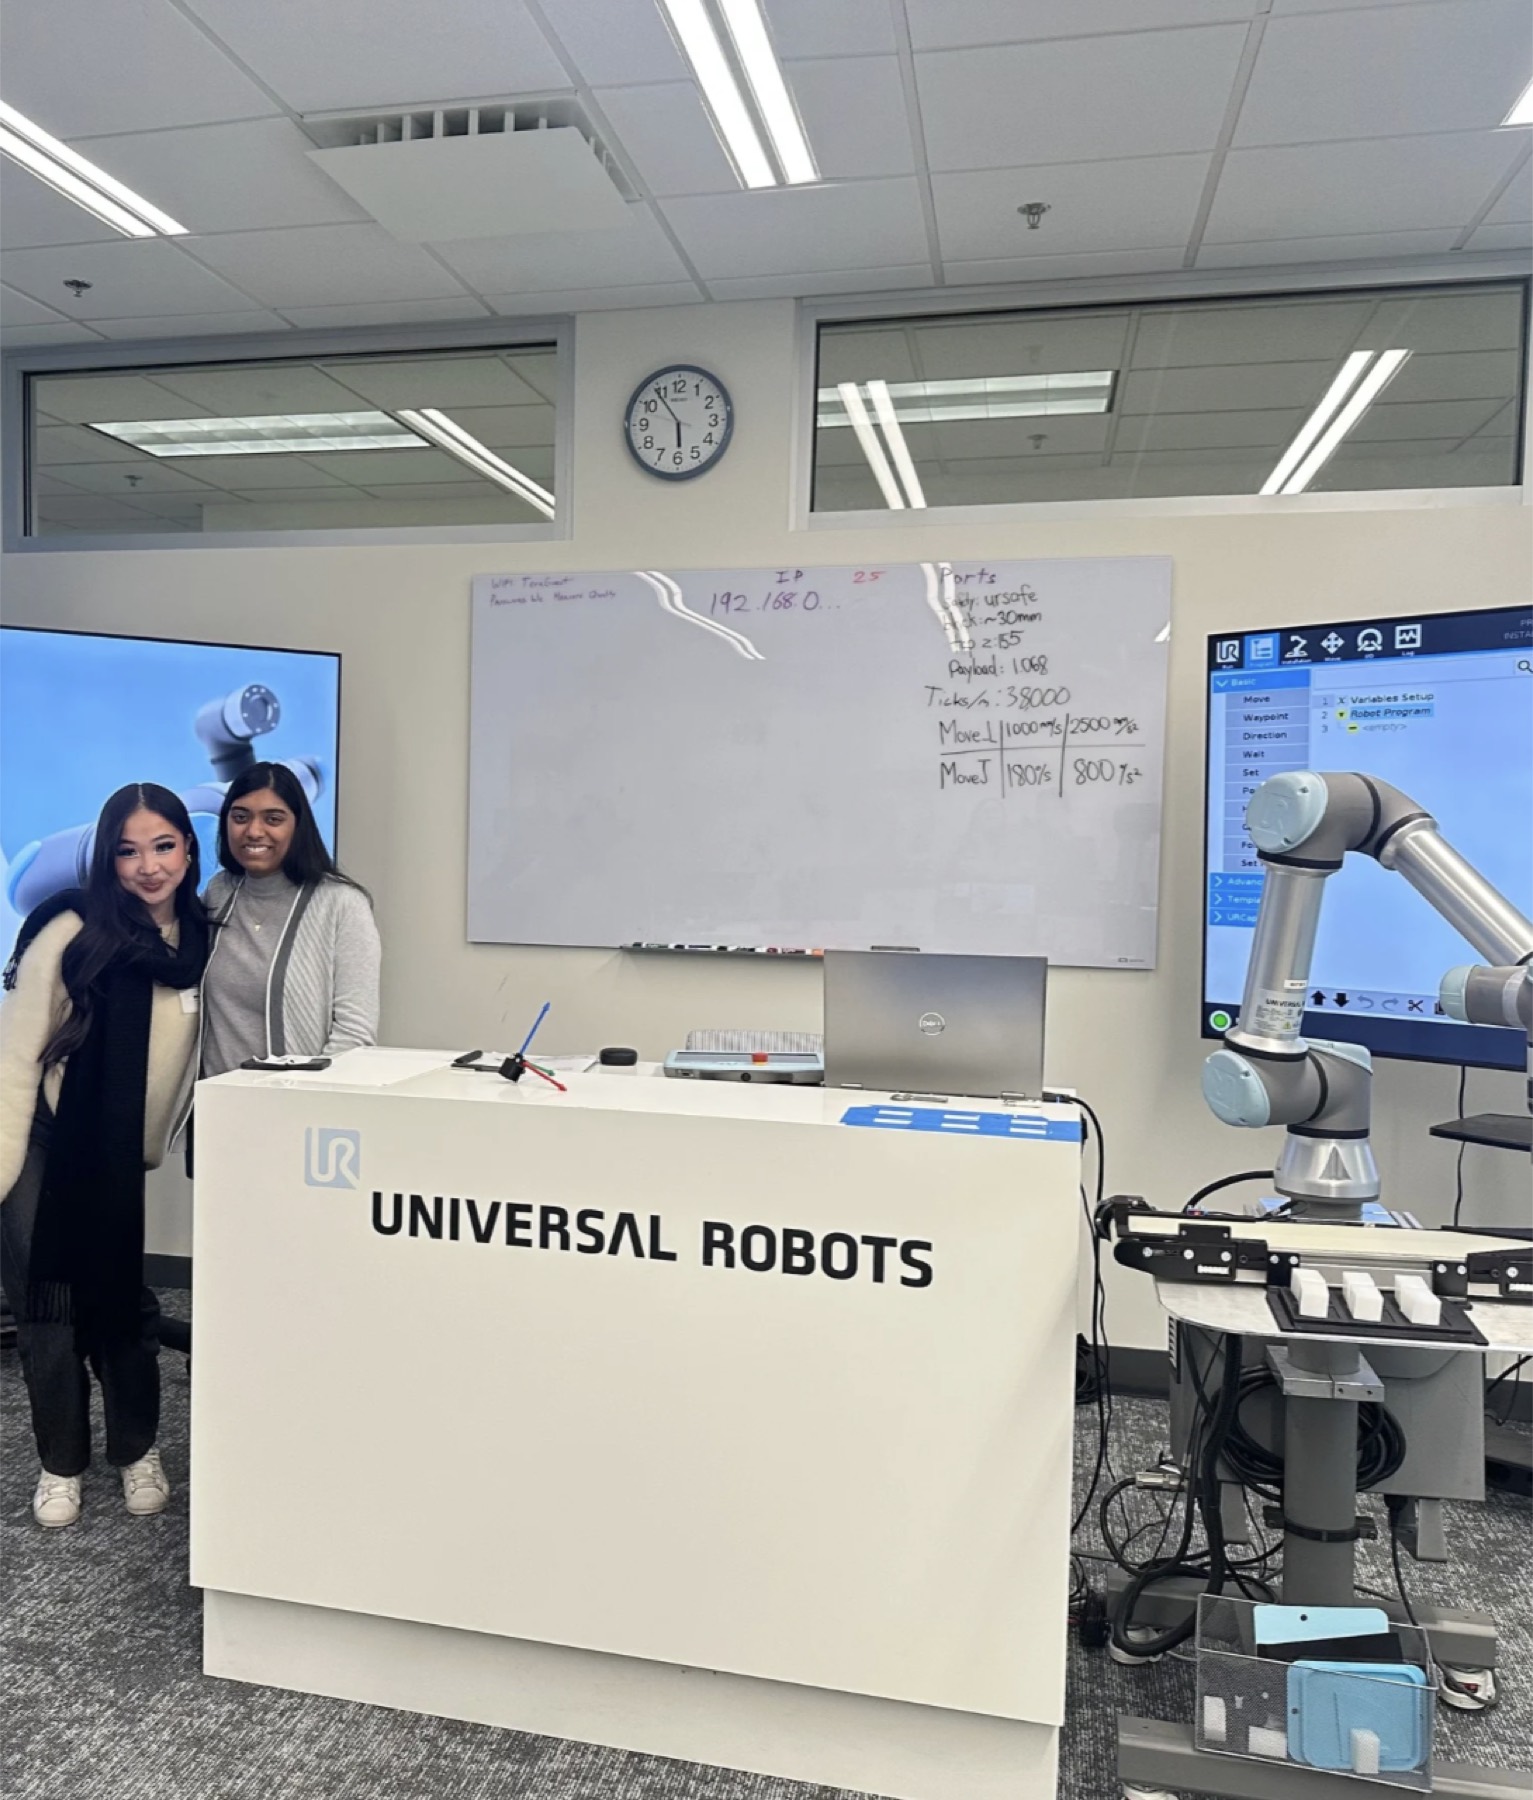
Veronika Wang beside a Universal Robots collaborative arm with program parameters on a whiteboard

Industrial manipulators & applied math

Time programming collaborative robot arms with mentors at Universal Robots and Robostreet, alongside five years of applied mathematics through Girls' Angle at Google — geometric modeling, algorithmic design, and simulation.

  • Manipulators
  • Modeling
  • Algorithms

03 Research interests

Areas I want to go deeper in

01

Multi-Agent Robotics

Coordination and task allocation across teams of autonomous robots operating with limited information.

02

Autonomous Systems

Robotic perception, navigation, planning, and decision-making in uncertain environments.

03

Computer Vision

Using visual and sensor information to detect, classify, map, and understand real-world environments.

04

Humanitarian Robotics

Engineering systems that support search-and-rescue, disaster response, and other high-impact applications.

05

UAVs & Mobile Robotics

Autonomous drones and ground vehicles for sensing, navigation, and field deployment.

06

AI for Physical Systems

Machine learning and decision-making for robots operating outside controlled environments.

04 Technical skills

Tools and methods

Described the way I'd describe them in person — what I use regularly, and what I've worked with on a specific project and am still learning.

01 Programming

  • Python
  • Java
  • C++
  • SQL

02 AI & Data

  • Machine learning fundamentals
  • Computer vision experiments
  • Experience with TensorFlow
  • Data analysis & visualization

03 Robotics

  • Prototype design & iteration
  • Sensor integration (LiDAR, thermal)
  • Autonomous system testing
  • Drone build & flight operations
  • Mechanical design basics

04 Research

  • Literature review
  • Experimental design & testing
  • Data interpretation
  • Technical presentation
  • Research communication

05 In a lab

What I can contribute

I'd come in expecting to learn far more than I contribute — but here is where I could be useful from the start.

Programming

Python, Java, and C++; data processing scripts; introductory machine learning workflows.

Robotics

Prototype development, sensor setup, robotics experimentation, and drone systems.

Research

Literature review, experimental support, data analysis, and careful documentation.

Communication

Technical presentations, writing, and working across disciplines with people who think differently.

Interested in the details?

I'm happy to send code, test data, design notes, or my poster to anyone who wants to look closer.